feat: Fix picture display problem
 Livox-SDK
@@ -1,11 +1,5 @@
|
|||||||
**在ROS驱动程序下使用lvx文件的方法**([How to use lvx file in ros](https://github.com/Livox-SDK/Livox-SDK/wiki/How-to-use-lvx-file-under-ros))
|
**在ROS驱动程序下使用lvx文件的方法**([How to use lvx file in ros](https://github.com/Livox-SDK/Livox-SDK/wiki/How-to-use-lvx-file-under-ros))
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
[TOC]
|
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
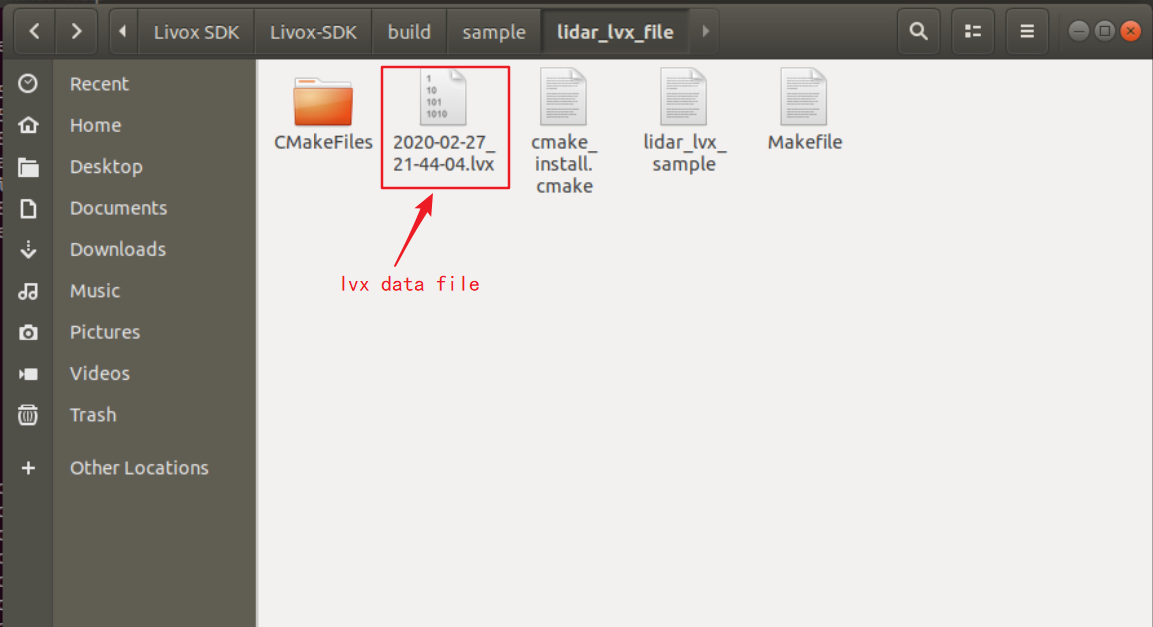
lvx文件是由览沃定义的点云存储格式;如果需要在ros中使用lvx文件,需要将其转换为rosbag文件。
|
lvx文件是由览沃定义的点云存储格式;如果需要在ros中使用lvx文件,需要将其转换为rosbag文件。
|
||||||
|
|
||||||
# 1、保存lvx格式的数据文件
|
# 1、保存lvx格式的数据文件
|
||||||
@@ -19,7 +13,7 @@ lvx文件是由览沃定义的点云存储格式;如果需要在ros中使用lv
|
|||||||
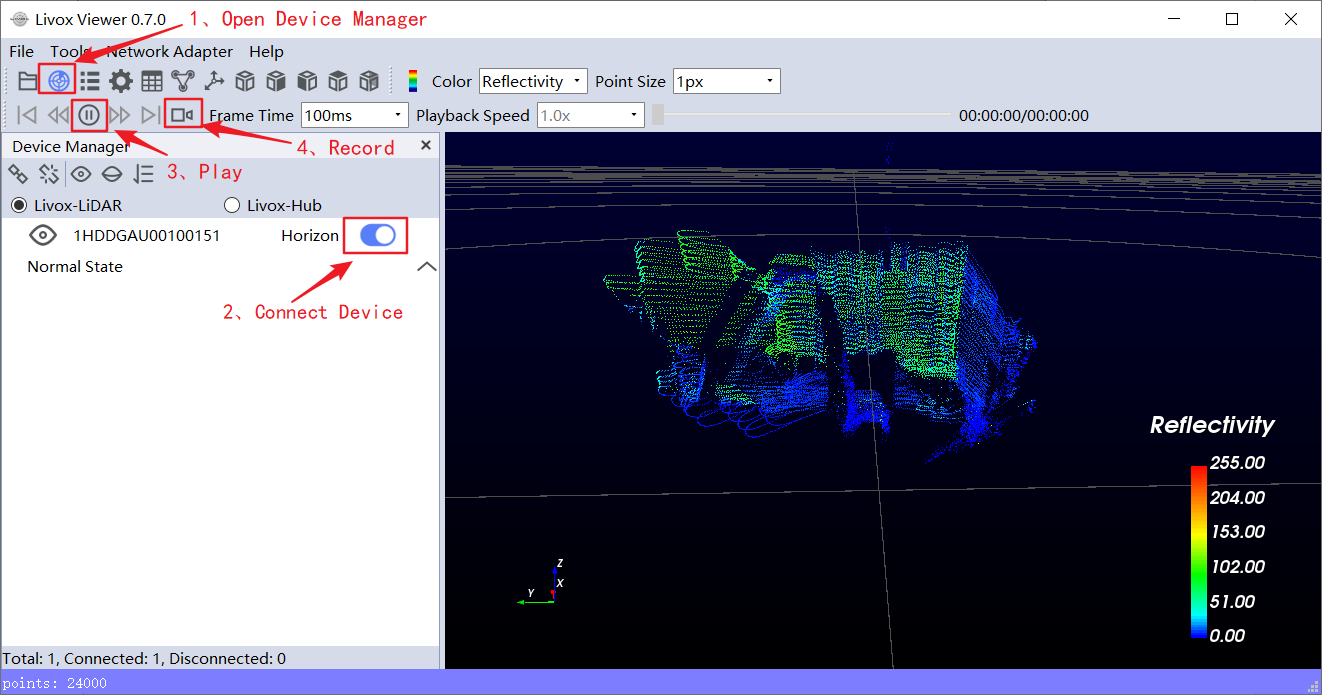
- 开始采样;
|
- 开始采样;
|
||||||
- 记录并保存lvx文件;
|
- 记录并保存lvx文件;
|
||||||
|
|
||||||
|

|
||||||
|
|
||||||
## 1.2 使用Livox-SDK保存lvx文件
|
## 1.2 使用Livox-SDK保存lvx文件
|
||||||
|
|
||||||
@@ -34,11 +28,11 @@ lvx文件是由览沃定义的点云存储格式;如果需要在ros中使用lv
|
|||||||
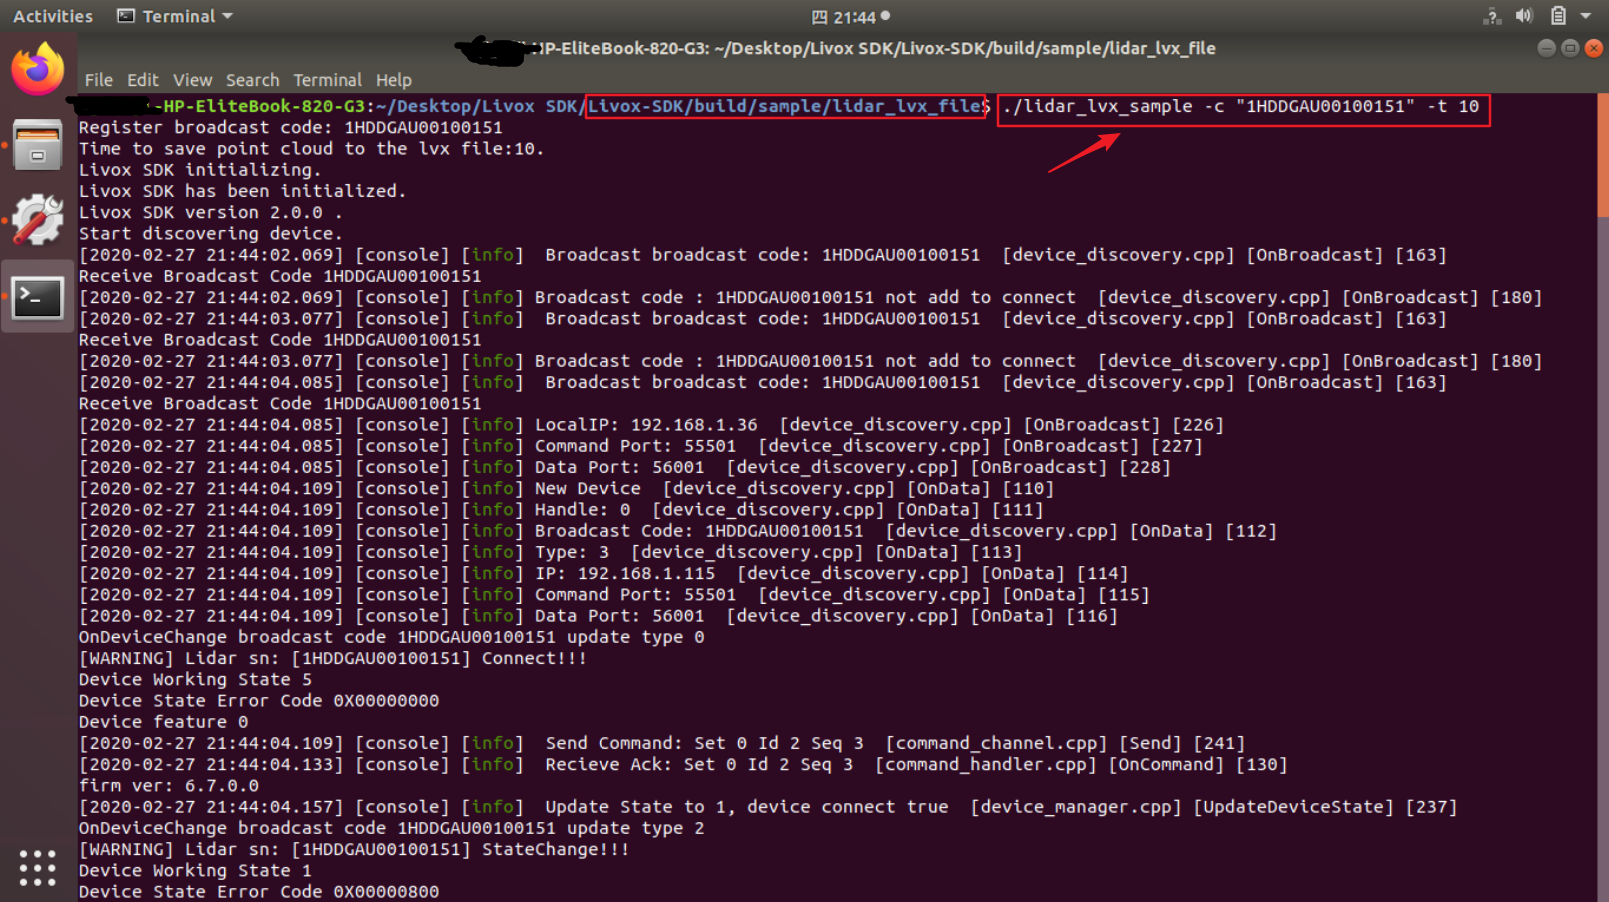
- 连接指定的设备: -c “Lidar SN”
|
- 连接指定的设备: -c “Lidar SN”
|
||||||
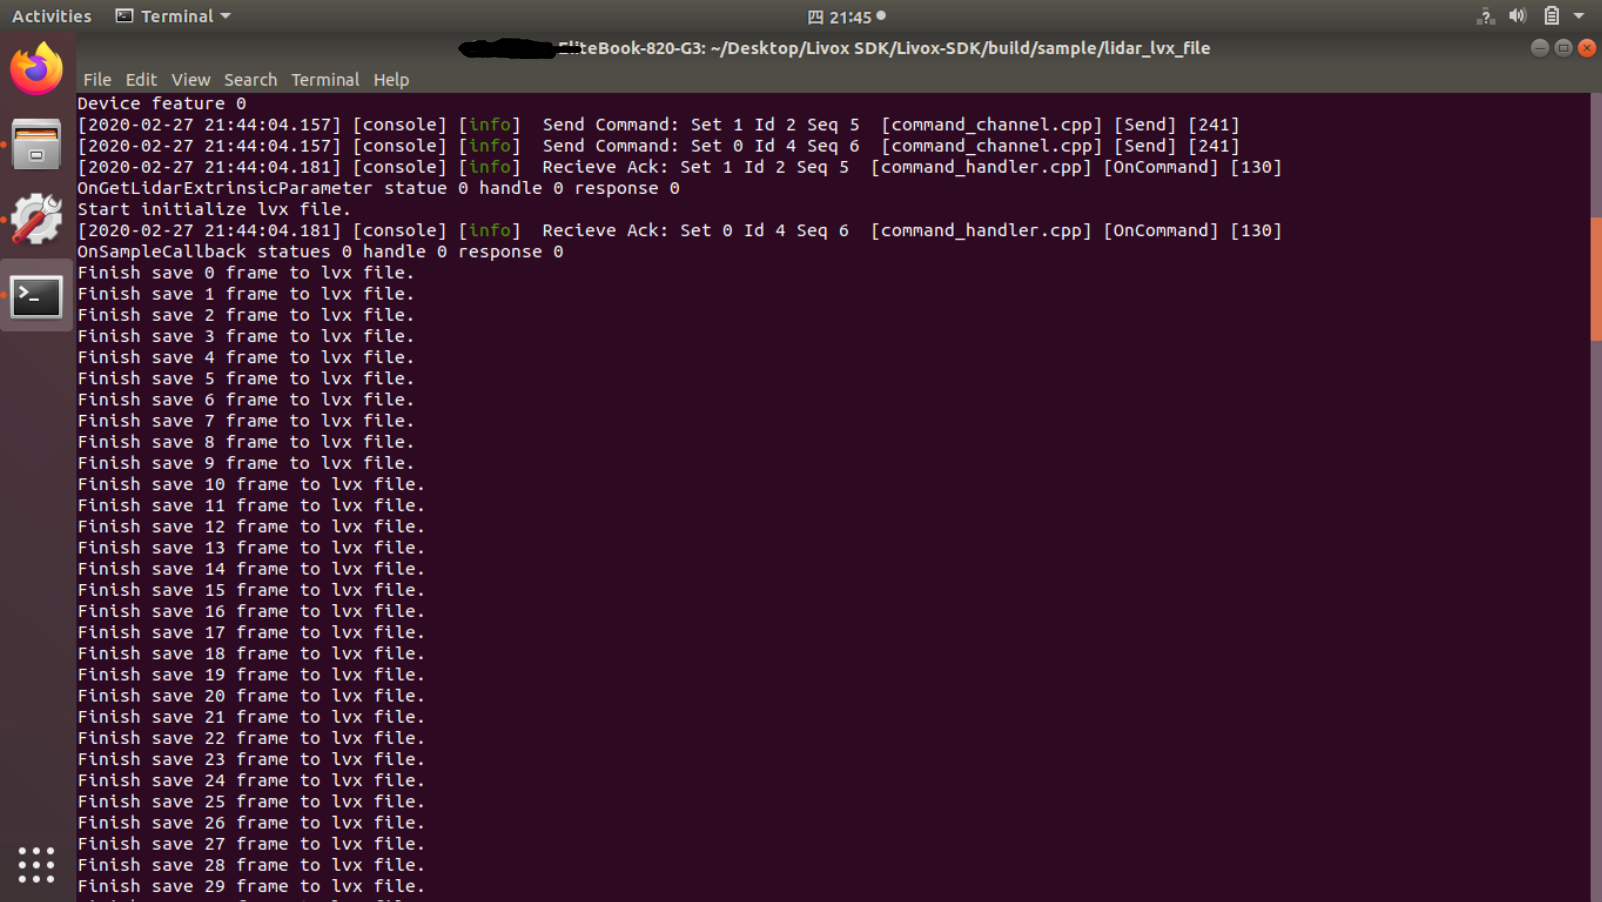
- 设置点云持续时间: -t 10 (10 second)
|
- 设置点云持续时间: -t 10 (10 second)
|
||||||
|
|
||||||
|

|
||||||
|
|
||||||
|

|
||||||
|
|
||||||
|

|
||||||
|
|
||||||
# 2 将lvx文件(v1.0/v1.1)转换为rosbag文件(仅支持Ubuntu系统)
|
# 2 将lvx文件(v1.0/v1.1)转换为rosbag文件(仅支持Ubuntu系统)
|
||||||
|
|
||||||
@@ -50,7 +44,7 @@ lvx文件是由览沃定义的点云存储格式;如果需要在ros中使用lv
|
|||||||
|
|
||||||
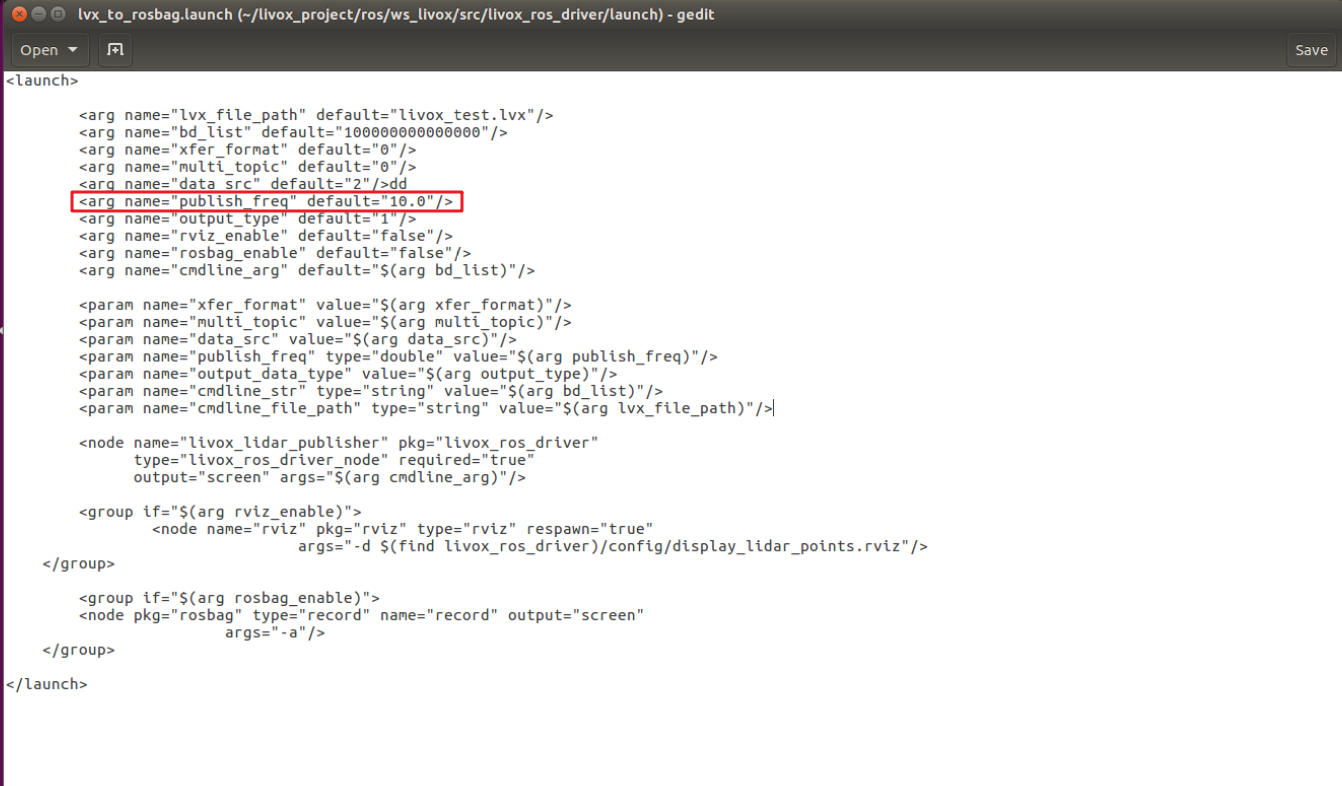
如果需要设置转换为rosbag数据的频率为10Hz,可以在 "../ws_livox/src/livox_ros_driver/launch/lvx_to_rosbag.launch file"文件中将‘publish_freq’参数设置为10.0。同理,可以将其设置成需要的频率。
|
如果需要设置转换为rosbag数据的频率为10Hz,可以在 "../ws_livox/src/livox_ros_driver/launch/lvx_to_rosbag.launch file"文件中将‘publish_freq’参数设置为10.0。同理,可以将其设置成需要的频率。
|
||||||
|
|
||||||
|

|
||||||
|
|
||||||
## 2.3 在以下路径打开终端窗口
|
## 2.3 在以下路径打开终端窗口
|
||||||
|
|
||||||
@@ -64,10 +58,10 @@ livox_ros_driver支持将lvx点云数据转换为rosbag文件。使用以下命
|
|||||||
|
|
||||||
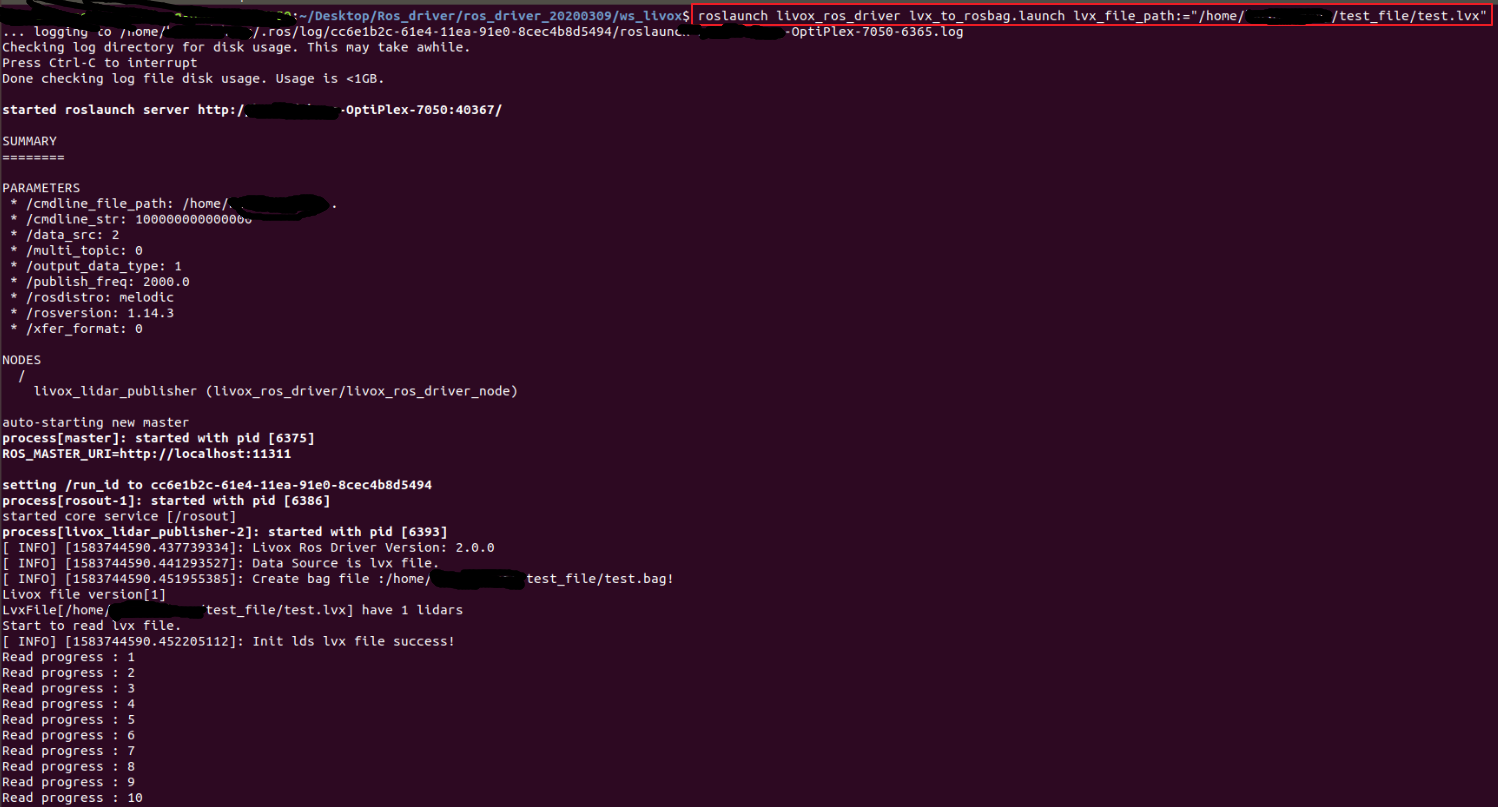
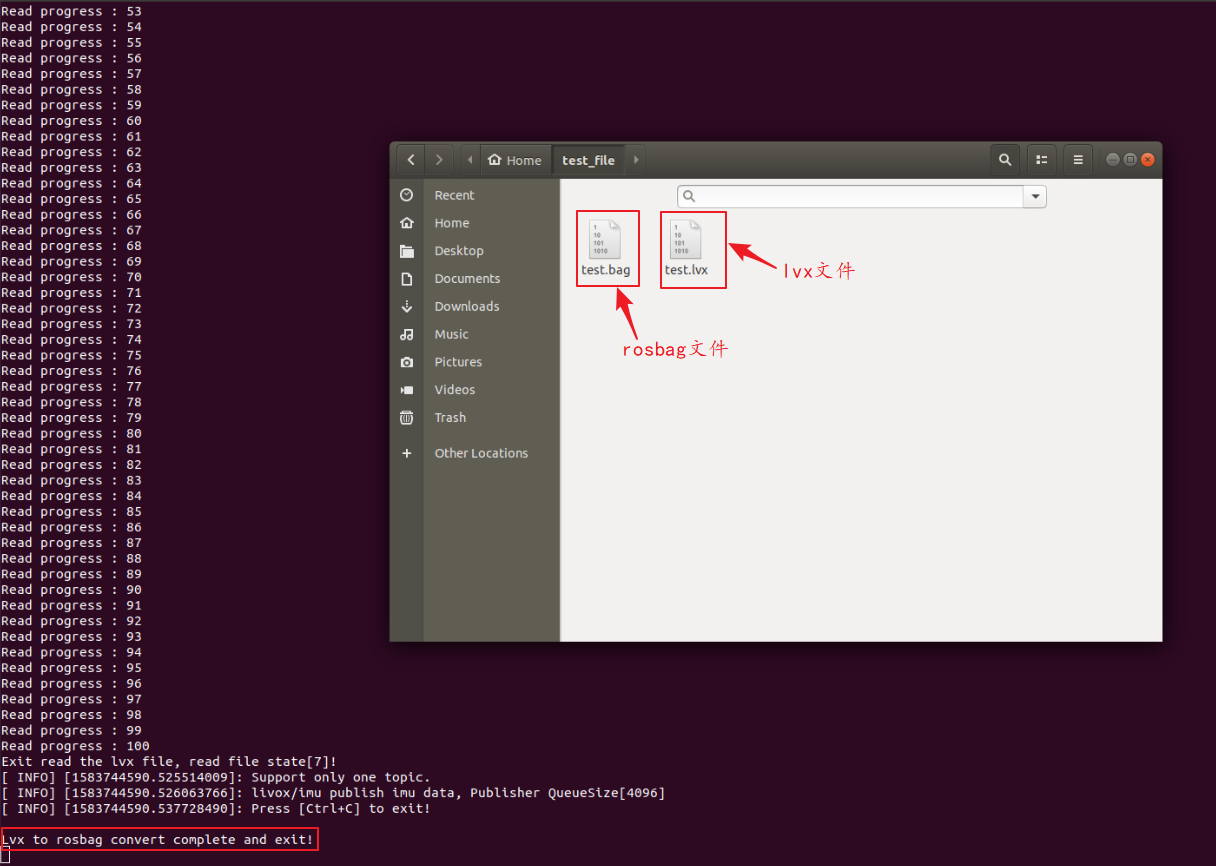
将上述命令中"/home/livox/test.lvx"替换为本地lvx文件的路径之后,即可以运行;如果转换成功,在上述路径下将会产生同名的rosbag格式的文件。
|
将上述命令中"/home/livox/test.lvx"替换为本地lvx文件的路径之后,即可以运行;如果转换成功,在上述路径下将会产生同名的rosbag格式的文件。
|
||||||
|
|
||||||
|

|
||||||
|
|
||||||
|

|
||||||
|
|
||||||
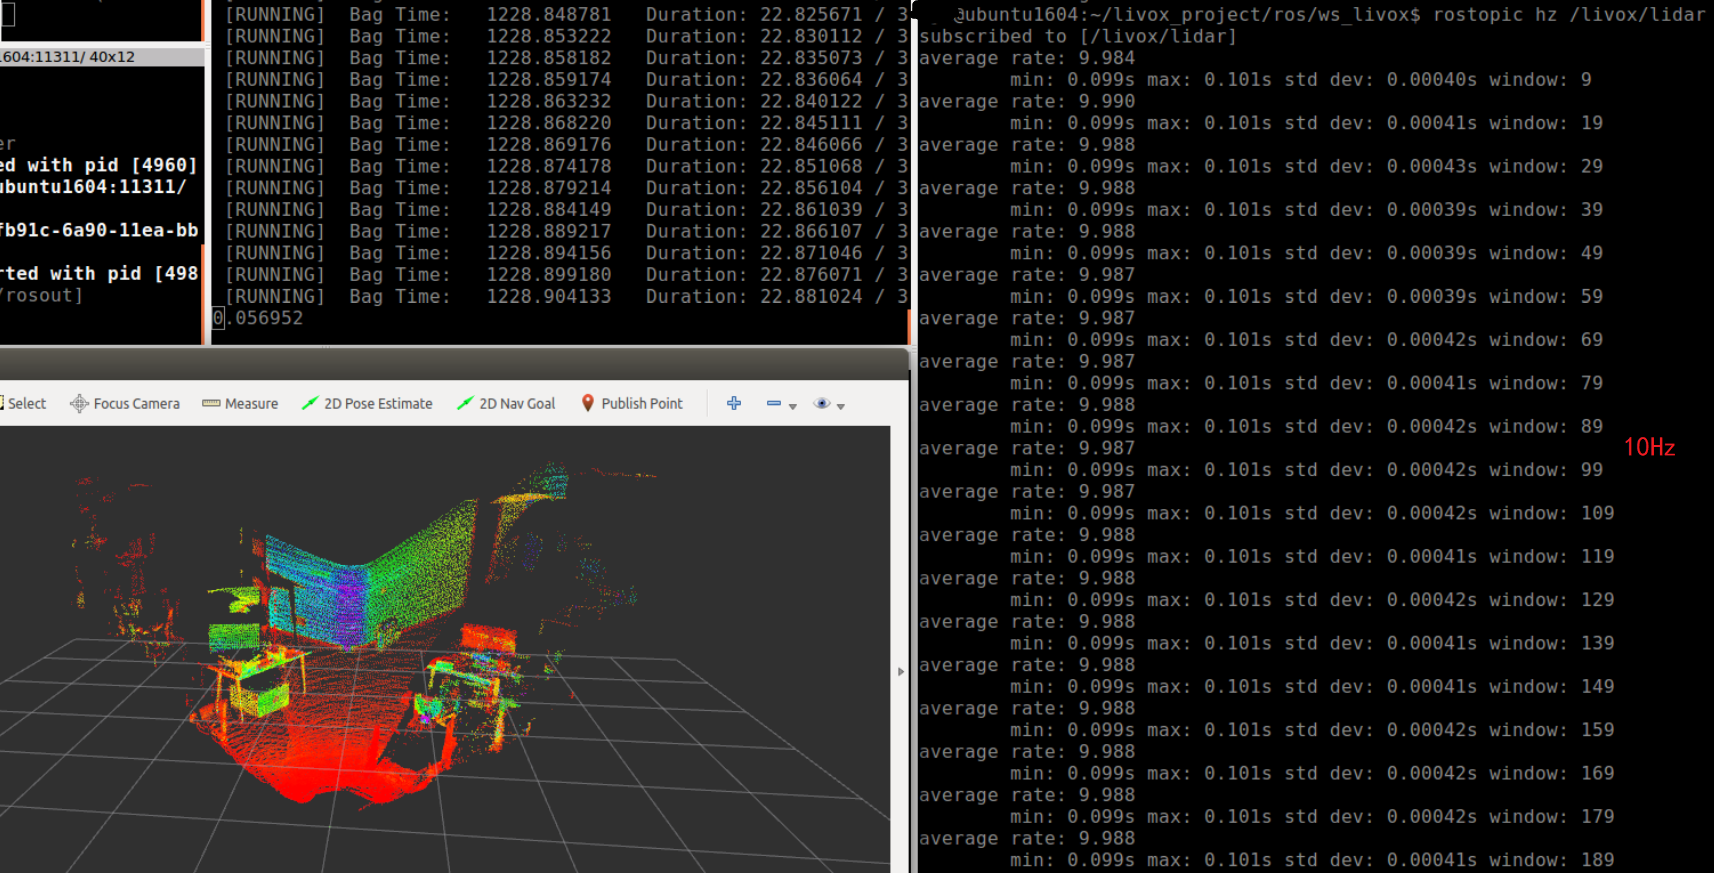
## 2.5 播放Rosbag数据
|
## 2.5 播放Rosbag数据
|
||||||
|
|
||||||
|

|
||||||
|
|||||||
@@ -1,11 +1,5 @@
|
|||||||
**How to use lvx file in ros**([在ROS驱动程序下使用lvx文件的方法](https://github.com/Livox-SDK/Livox-SDK/wiki/How-to-use-lvx-file-under-ros-cn))
|
**How to use lvx file in ros**([在ROS驱动程序下使用lvx文件的方法](https://github.com/Livox-SDK/Livox-SDK/wiki/How-to-use-lvx-file-under-ros-cn))
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
[TOC]
|
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
lvx is a point cloud storage format customized by livox; if you want to use lvx file in ros, you need to convert it to rosbag file.
|
lvx is a point cloud storage format customized by livox; if you want to use lvx file in ros, you need to convert it to rosbag file.
|
||||||
|
|
||||||
# 1. Save lvx data file
|
# 1. Save lvx data file
|
||||||
|
|||||||
+4
-10
@@ -1,11 +1,5 @@
|
|||||||
**在Ros中设置发布频率**([Set publish frequency](https://github.com/Livox-SDK/Livox-SDK/wiki/Set-publish-frequency))
|
**在Ros中设置发布频率**([Set publish frequency](https://github.com/Livox-SDK/Livox-SDK/wiki/Set-publish-frequency))
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
[TOC]
|
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
# 1. Git clone livox_ros_driver
|
# 1. Git clone livox_ros_driver
|
||||||
|
|
||||||
`git clone https://github.com/Livox-SDK/livox_ros_driver.git ws_livox/src`
|
`git clone https://github.com/Livox-SDK/livox_ros_driver.git ws_livox/src`
|
||||||
@@ -16,7 +10,7 @@
|
|||||||
|
|
||||||
如果需要设置转换为rosbag数据的频率为10Hz,可以在 "../ws_livox/src/livox_ros_driver/launch/lvx_to_rosbag.launch file"文件中将‘publish_freq’参数设置为10.0。同理,可以将其设置成需要的频率。
|
如果需要设置转换为rosbag数据的频率为10Hz,可以在 "../ws_livox/src/livox_ros_driver/launch/lvx_to_rosbag.launch file"文件中将‘publish_freq’参数设置为10.0。同理,可以将其设置成需要的频率。
|
||||||
|
|
||||||

|

|
||||||
|
|
||||||
# 3. 在以下路径打开终端窗口
|
# 3. 在以下路径打开终端窗口
|
||||||
|
|
||||||
@@ -30,10 +24,10 @@ livox_ros_driver支持将lvx点云数据转换为rosbag文件。使用以下命
|
|||||||
|
|
||||||
将上述命令中"/home/livox/test.lvx"替换为本地lvx文件的路径之后,即可以运行;如果转换成功,在上述路径下将会产生同名的rosbag格式的文件。
|
将上述命令中"/home/livox/test.lvx"替换为本地lvx文件的路径之后,即可以运行;如果转换成功,在上述路径下将会产生同名的rosbag格式的文件。
|
||||||
|
|
||||||

|

|
||||||
|
|
||||||

|

|
||||||
|
|
||||||
# 5. 播放rosbag数据
|
# 5. 播放rosbag数据
|
||||||
|
|
||||||

|

|
||||||
|
|||||||
@@ -1,11 +1,5 @@
|
|||||||
**Set publish frequency**([在ROS驱动程序中设置发布频率](https://github.com/Livox-SDK/Livox-SDK/wiki/Set-publish-frequency-cn))
|
**Set publish frequency**([在ROS驱动程序中设置发布频率](https://github.com/Livox-SDK/Livox-SDK/wiki/Set-publish-frequency-cn))
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
[TOC]
|
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
# 1. Git clone livox_ros_driver
|
# 1. Git clone livox_ros_driver
|
||||||
|
|
||||||
`git clone https://github.com/Livox-SDK/livox_ros_driver.git ws_livox/src`
|
`git clone https://github.com/Livox-SDK/livox_ros_driver.git ws_livox/src`
|
||||||
|
|||||||
@@ -2,12 +2,6 @@
|
|||||||
|
|
||||||
**Livox设备时间同步**([livox device time synchronization manual](https://github.com/Livox-SDK/Livox-SDK/wiki/livox-device-time-synchronization-manual))
|
**Livox设备时间同步**([livox device time synchronization manual](https://github.com/Livox-SDK/Livox-SDK/wiki/livox-device-time-synchronization-manual))
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
[TOC]
|
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
# 1 时间同步说明
|
# 1 时间同步说明
|
||||||
|
|
||||||
Livox设备支持3种时间同步方式:
|
Livox设备支持3种时间同步方式:
|
||||||
|
|||||||
@@ -2,12 +2,6 @@
|
|||||||
|
|
||||||
**Livox device time synchronization**([livox设备时间同步说明中文文档](https://github.com/Livox-SDK/Livox-SDK/wiki/livox-device-time-synchronization-manual-cn))
|
**Livox device time synchronization**([livox设备时间同步说明中文文档](https://github.com/Livox-SDK/Livox-SDK/wiki/livox-device-time-synchronization-manual-cn))
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
[TOC]
|
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
# 1 Time synchronization instructions
|
# 1 Time synchronization instructions
|
||||||
|
|
||||||
Livox devices support 3 time synchronization methods:
|
Livox devices support 3 time synchronization methods:
|
||||||
|
|||||||
Reference in New Issue
Block a user